Constraint-Aware Speed Planning under Curved Road Conditions for Smart Regenerative Braking using an Analytical Minimum-Jerk Approach
- Abstract
Achieving smooth and predictable deceleration during cornering remains a critical challenge for smart regenerative braking systems (SRS) in electric vehicles (EVs), particularly when fixed deceleration strategies fail to reflect driver preferences and varying road geometries.
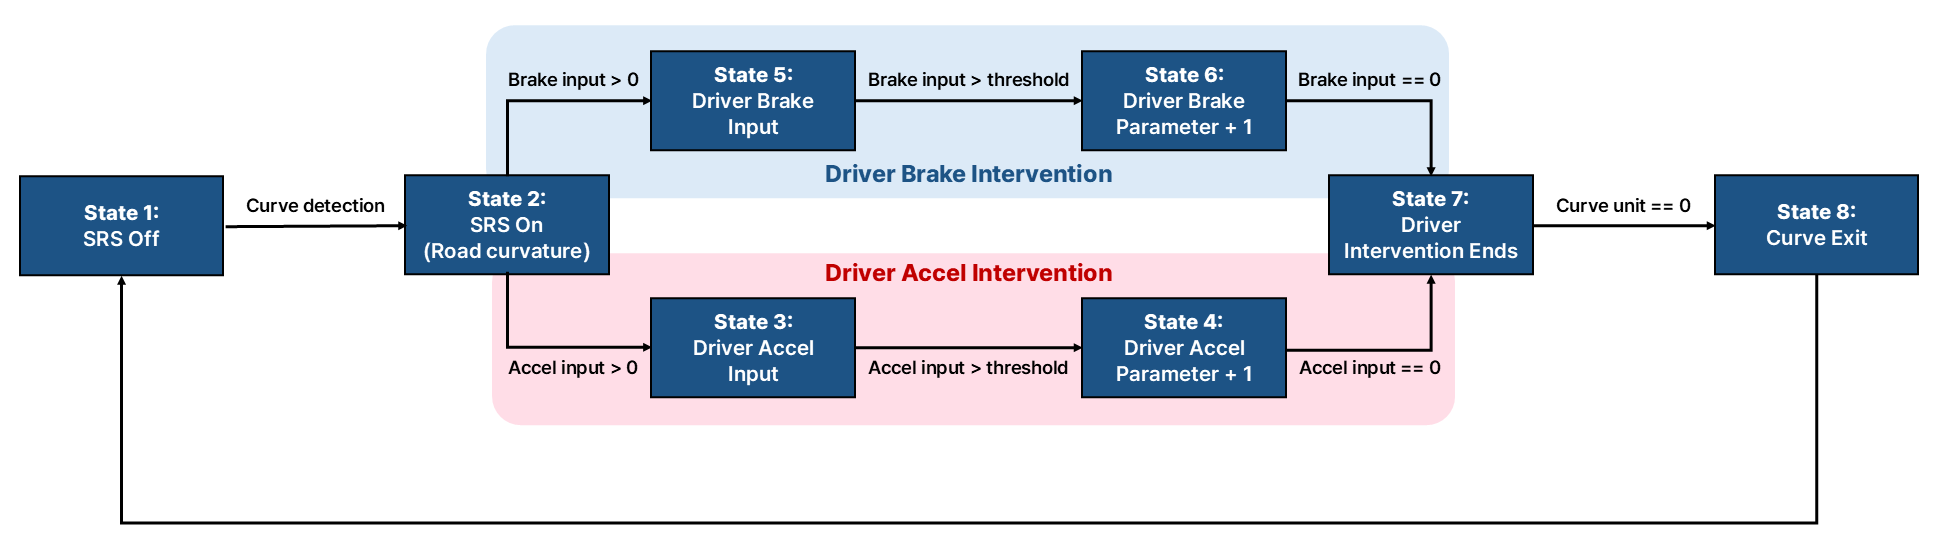
This paper presents a constraint-aware speed planning framework for curvature-induced deceleration in EVs equipped with SRS. A minimum-jerk-based analytical formulation is employed to generate continuous and human-centered deceleration profiles, while an efficient time-adjustment mechanism ensures compliance with longitudinal acceleration constraints without iterative numerical optimization, enabling real-time implementation. In addition, a driver-adaptive target speed update strategy is introduced, which adjusts curvature-based target speeds based on driver pedal interventions to reflect individual driving tendencies during SRS operation.
The proposed framework is implemented in a vehicle control unit and validated through simulation and real-vehicle experiments. The results demonstrate that the proposed method provides feasible and smooth deceleration under varying curvature conditions, reduces driver pedal interventions, and improves deceleration comfort during cornering. These improvements contribute to enhanced drivability and increased utilization of regenerative braking in EVs.