Model Predictive Control for Active Rear Steering Without Sideslip-Angle Feedback
- Abstract
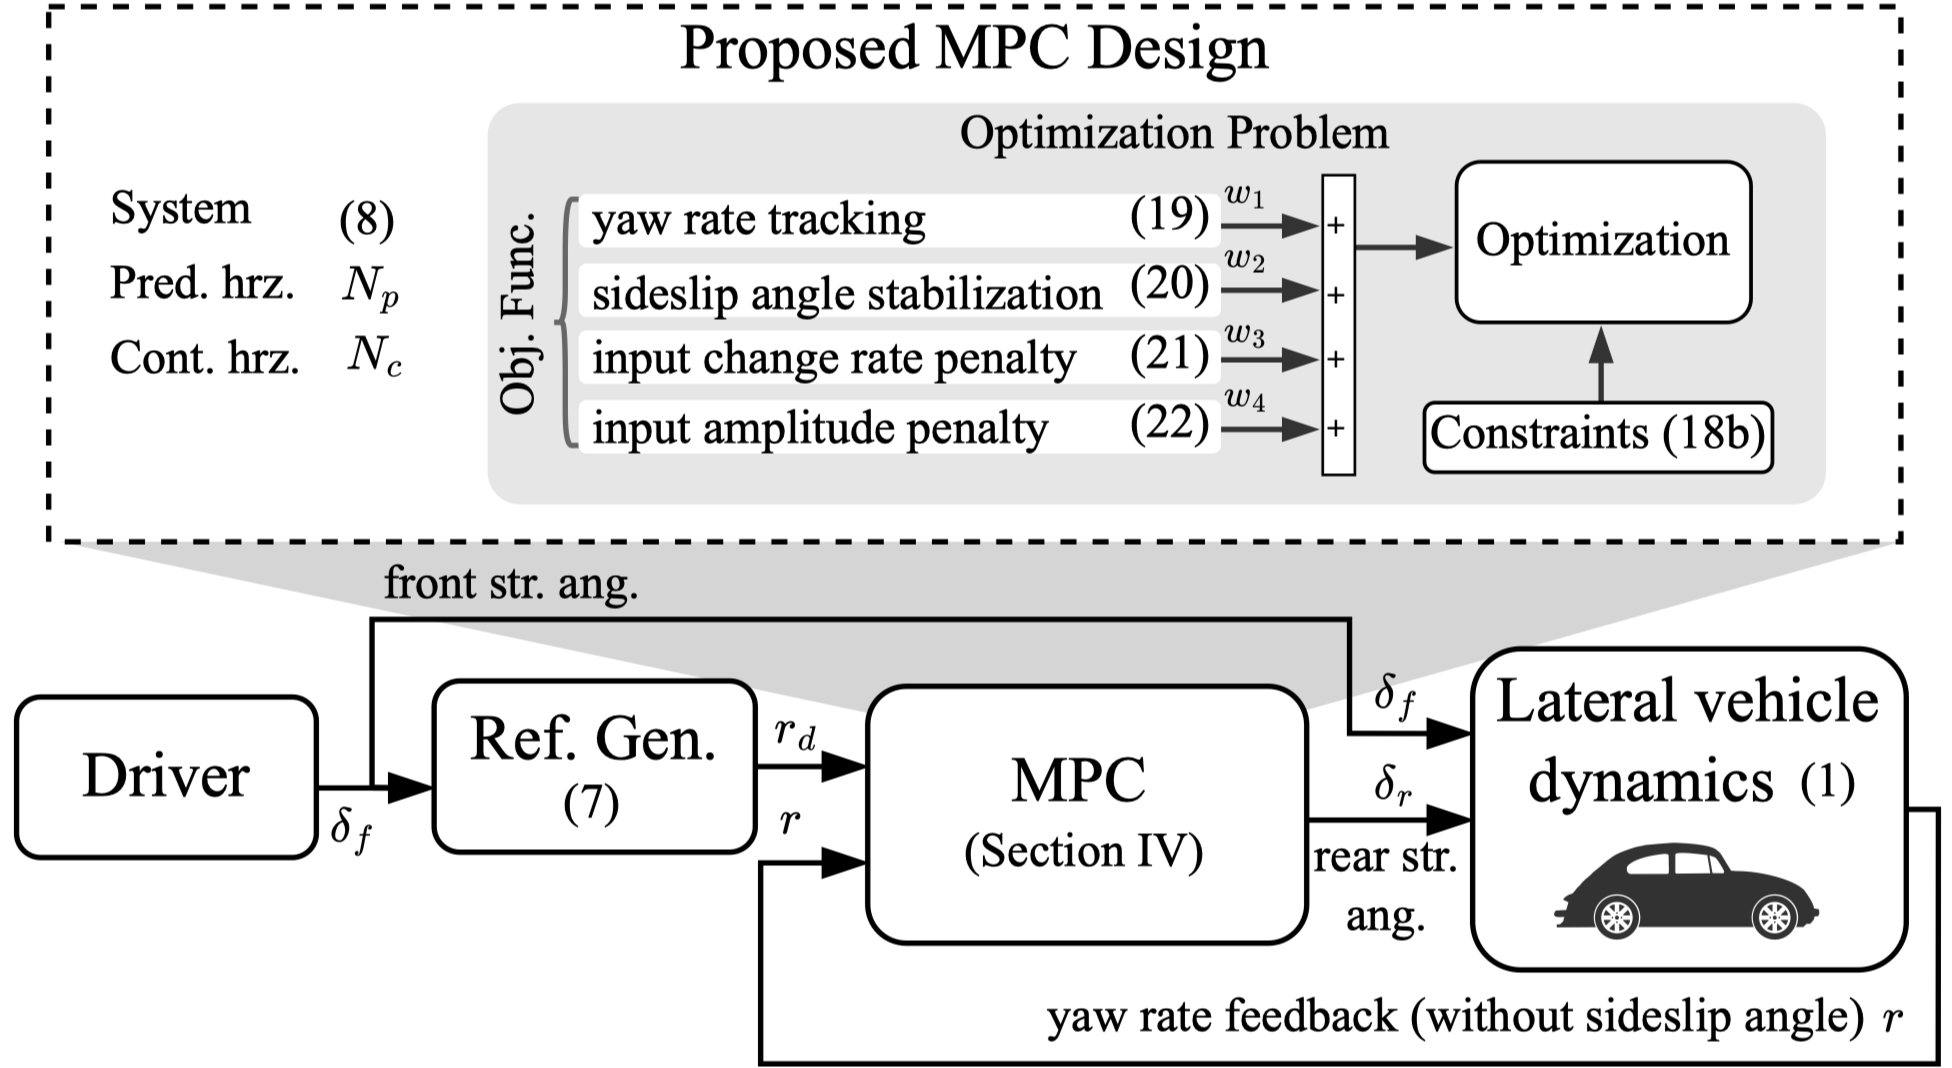
This paper proposes a model predictive control (MPC) method for active rear steering (ARS) that does not require sideslip-angle feedback. ARS control can improve vehicle maneuverability and lateral stability while preserving the driver’s steering intention through the front wheels. However, conventional ARS controllers commonly rely on the vehicle sideslip angle, which must be obtained through direct sensing or online estimation and may therefore introduce sensing or estimation errors into the feedback loop. To eliminate this dependence, the proposed MPC employs two complementary mechanisms. First, the yaw rate is predicted without using the sideslip angle by exploiting its limited influence on finite-horizon yaw-rate prediction under the considered operating conditions. Second, sideslip-angle attenuation is promoted by suppressing a residual term in the sideslip-angle dynamics that is independent of the sideslip angle itself. These two mechanisms enable the MPC optimization to be formulated using yaw-rate and steering signals without requiring measured or estimated sideslip-angle feedback. Numerical simulations demonstrate that the proposed controller maintains satisfactory yaw-rate tracking and sideslip suppression while remaining insensitive to sideslip-angle feedback errors.