Online Learning of Control-Oriented Lateral Tire-Force Maps for Vehicle MPC
- Abstract
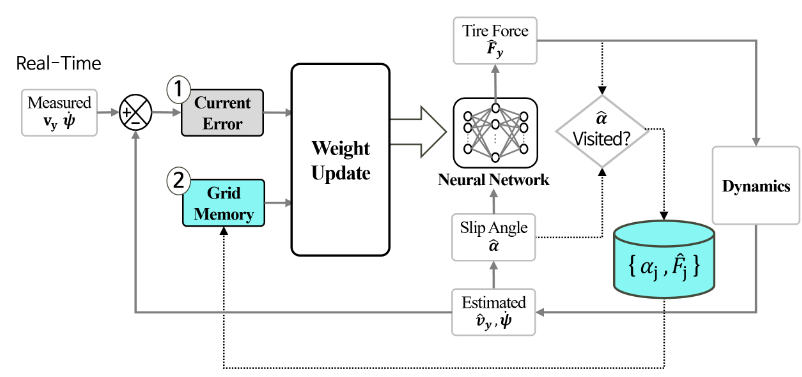
Vehicle model predictive control (MPC) repeatedly evaluates a tire-force model at predicted slip angles over its prediction horizon. Hence, an instantaneous force correction is insufficient: the learned object should be a reusable slip-angle-indexed map. This paper presents an online method that updates front and rear lateral tire-force maps from lateral–yaw state errors without direct tire-force measurements. A neural identifier supplies the instantaneous adaptation signal, while a predefined slip-angle table retains the learned relation over the previously excited domain. CarMaker simulations with changing tire characteristics and steering transitions show that the proposed method reduces trajectory force errors and frozen-horizon prediction errors compared with instantaneous and recent-window updates. The resulting compact model can be directly evaluated inside a vehicle MPC prediction horizon.