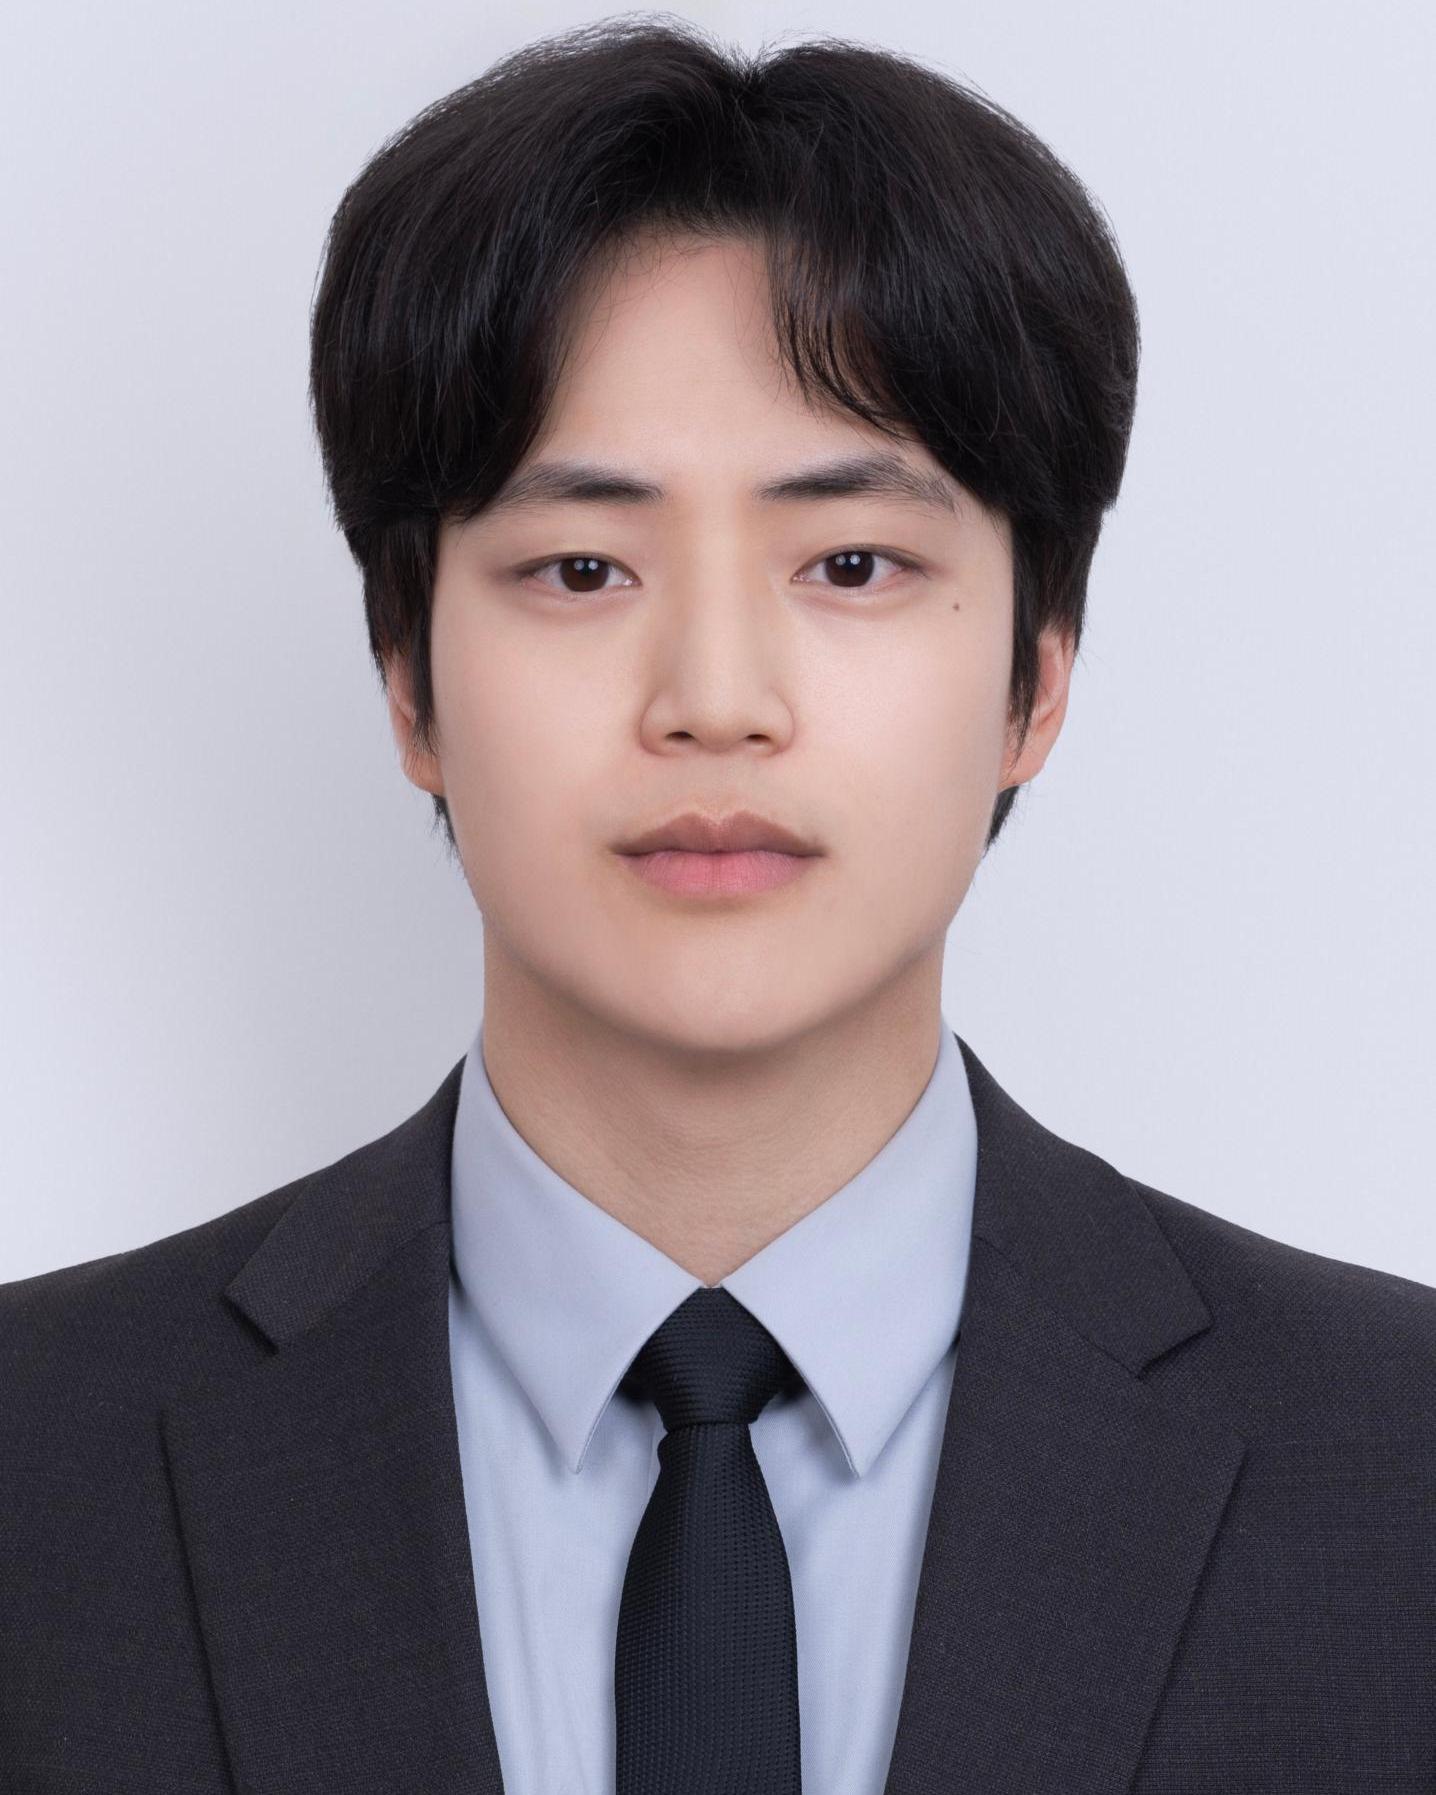
Researcher
fairytale@kaist.ac.kr
 0009-0001-2462-6249
 Google Scholar
 fairytalef00
 12765248
Description
Donghwa Hong is a Researcher at the Cho Chun Shik Graduate School of Mobility, KAIST, and a member of the Mobility Intelligence and Control Laboratory (MIC Lab).
His research focuses on learning-based identification of uncertain dynamics and state and parameter estimation, with applications to vehicle and robotic systems.
He received his B.S. degree in Physics from Yonsei University (Wonju) in 2023 and his M.S. degree in Mechanical and Robotics Engineering from the Gwangju Institute of Science and Technology (GIST) in 2026.
News & Events
Projects
-
[Hyundai Motor Company] Development of RWS Control Logic for Improved Driving Performance and Tunability (Year 2)
[현대자동차] 주행성능 향상 및 튜닝성 개선을 위한 RWS제어로직 개발(2차년도)
- Researcher (2026.09.07 - Ongoing)
-
[Hyundai Motor Company] Development of RWS Control Logic for Improved Driving Performance and Tunability (Year 1)
[현대자동차] 주행성능 향상 및 튜닝성 개선을 위한 RWS제어로직 개발(1차년도)
- Researcher (2025.06.23 - 2026.06.22)
-
[Ministry of National Defense] Ultra-Immersive Training Technologies for Infantry Combat Skills
[국방부] 초실감 보병 전투 기술 훈련 기술
- Lead Researcher (2022.12.01 - Ongoing)
Publications
Quick Links
- Papers Under Review (1)
- International Conference Papers (2)
- Domestic Conference Papers (1)
- Master's Theses (1)
Papers Under Review
-
[New] Constrained Optimization-Based Neuro-Adaptive Control (CONAC) for Unknown Systems Under Multiple Convex Input Constraints
Myeongseok Ryu, Donghwa Hong , Kyunghwan Choi*
Withheld during double-blind review , 2027
2026
International Conference Papers
-
Online Learning of Control-Oriented Lateral Tire-Force Maps for Vehicle MPC
Donghwa Hong , Kyunghwan Choi*
International Workshop on Intelligent Systems (IWIS) , pp. 1-4, 2026 [🌐 Online] -
Integral Error-Based Adaptive Neural Identifier for Nonlinear Lateral Tire Forces
Donghwa Hong , Kyunghwan Choi*
IEEE International Conference on Advanced Motion Control (AMC) , pp. 1-6, 2026 [🌐 Online] [📃 Full-Text]
2026
Domestic Conference Papers
-
State-Error-Based Online Learning of Control-Oriented Tire Force Models Using Grid Memory
제어 지향 타이어 횡력 모델의 그리드 메모리를 이용한 상태 오차 기반 온라인 학습
Donghwa Hong , Kyunghwan Choi*
제어로봇시스템학회 (ICROS) , pp. 843-844, 2026 [🌐 DBpia Online] [📃 Full-Text]
2026
Master's Theses
-
Integral Error-Based Adaptive Neural Identifier for a Class of Uncertain Nonlinear Systems
Donghwa Hong , Kyunghwan Choi*
Gwangju Institute of Science and Technology (GIST) Library, 2026 [📃 Full-Text]