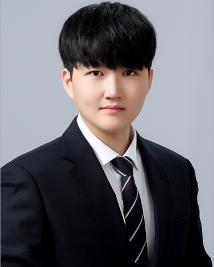
Ph.D. Student
hyochanlee@kaist.ac.kr
 0000-0002-7445-7412
 Google Scholar
 HyochanLee1007
 12678429
Description
Hyochan Lee received the B.S. and M.S. degrees in the Department of Creative Convergence Engineering from Hanbat National University, Daejeon, South Korea, in 2023 and 2024, respectively. He is currently pursuing the Ph.D. degree in the Cho Chun Shik Graduate School of Mobility at the KAIST, Daejeon, South Korea.
His current research interests include intelligent control of mobility systems using reinforcement learning and deep learning, tracking control of electromechanical systems, and the development of advanced control theories such as nonlinear adaptive control, optimal control, and learning-based control.
News & Events
Projects
-
[SNT모티브] Development of Inverters and Drive Control Technologies for High-Precision, High-Efficiency Automotive Engine Oil Pump Drives
[SNT모티브] 차량 엔진 오일 펌프용 고정밀·고효율 구동을 위한 인버터 및 구동 제어 기술 개발
- Lead Researcher (2026.04.27 - Ongoing)
-
[KAIST 모빌리티 AX 연구소] Development of Robot-Based Cooperative Transport Technologies for Heavy-Load Logistics
[KAIST 모빌리티 AX 연구소] 고하중 물류 운송을 위한 로봇 기반 협력 운송 기술 개발
- Lead Researcher (2025.07.01 - 2026.05.31)
Publications
Quick Links
- International Journal Papers (1)
- International Conference Papers (4)
- Domestic Journal Papers (1)
- Domestic Conference Papers (3)
International Journal Papers
-
Output-Feedback Multi-Loop Positioning Technique via Dual Motor Synchronization Approach for Elevator System Applications
Hyochan Lee , Hyeoncheol Lee, Jaekwang Lee, Hyunduck Choi, Kyunghwan Choi, Younghun Kim, Seokkyoon Kim*
Energies , vol. 15, no. 23, pp. , 2022 [🌐 Online]
2022
International Conference Papers
-
Online Constrained Reinforcement Learning for Optimal Tracking
Hyochan Lee , Kyunghwan Choi*
International Federation of Automatic Control (IFAC) World Congress (accepted, in press), 2026 [📃 Full-Text] -
Constrained Optimization Formulation of Bellman Optimality Equation for Online Reinforcement Learning
Hyochan Lee , Kyunghwan Choi*
International Conference on Robot Intelligence Technology and Applications (RiTA) (accepted, in press), 2025 [📃 Full-Text] -
Using Deep Reinforcement Learning for Dynamic Gain Adjustment of a Disturbance Observer
Hyochan Lee , Kyunghwan Choi*, Wooyong Kim*
International Conference on Control, Automation and Systems (ICCAS) , pp. 1273-1278, 2025 [🌐 Online] -
Online Actor Critic Learning for Optimal Tracking in Servo Positioning Systems
Hyochan Lee , Kyunghwan Choi*
Annual Conference of the IEEE Industrial Electronics Society (IECON) , pp. 1-7, 2025 [🌐 Online] [📃 Full-Text]
2026
2025
Domestic Journal Papers
-
Speed Tracking for Servo Systems via Active Pole-Zero Cancellation Stabilization Technique
서보 시스템 응용을 위한 능동형 영-극점 상쇄 속도 추종 기술
Hyochan Lee , Youngseok Lee, Kyunghwan Choi, Seokkyoon Kim*
Journal of Institute of Control, Robotics and Systems , vol. 28, no. 11, pp. 1045-1051, 2022 [🌐 Online]
2022
Domestic Conference Papers
-
Constrained Optimization Formulation of Bellman Optimality Equation for Online Reinforcement Learning
온라인 강화학습을 위한 벨만 최적 방정식의 제약 최적화 문제
Hyochan Lee , Kyunghwan Choi*
제어로봇시스템학회 (ICROS) , pp. 557-558, 2026 [🌐 DBpia Online] [📃 Full-Text] -
Online Reinforcement Learning for Optimal Tracking in Servo Positioning Systems
온라인 강화학습 기반 서보 시스템의 최적 각도 추종 제어
Hyochan Lee , Kyunghwan Choi*
제어로봇시스템학회 (ICROS) , pp. 727-728, 2025 [🌐 DBpia Online] [📃 Full-Text] -
Using Deep Reinforcement Learning for Intelligent Gain Adjustment of a Disturbance Observer
외란관측기의 심층강화학습 기반 지능형 자동 동조 기법
Hyochan Lee , Kyunghwan Choi*
제어로봇시스템학회 (ICROS) , pp. 292-293, 2024 [🌐 DBpia Online] [📃 Full-Text]